-
Products -PCBA Manufacturing RF Connectors RF Cable Assemblys Embedded Antennas External Antennas GNSS Positioning Solutions
RF Connectors

RF Cable Assemblys
Embedded Antennas
External Antennas
GNSS Positioning Solutions
 Language


Language
Model: TX-ZED-F9P-04B-MINI
The TOXU TX-ZED-F9P-04B-MINI is a compact RTK GNSS receiver board built around the u-blox ZED-F9P-04B-01 module. It is designed for OEM teams integrating dual-frequency positioning into UAVs, mobile robots and other equipment with limited mounting space.
u-blox ZED-F9P-04B-01 Module
Tracks GPS L1 and L2 alongside supported GLONASS, Galileo, BeiDou and QZSS signals.
RTK Positioning with RTCM Corrections
Supports centimeter-level positioning under suitable reception conditions with compatible RTCM correction data.
External Active GNSS Antenna
Allows the antenna to be mounted where it has a clear view of the sky while the receiver board sits inside the equipment.
NMEA and UBX Position Data
The module supports standard NMEA messages and u-blox UBX messages for compatible host software.
Compact PCB with Four Mounting Holes
The rectangular layout supports mounting on standoffs or a carrier plate inside an OEM enclosure.
The TOXU TX-ZED-F9P-04B-MINI is a compact RTK GNSS receiver board equipped with the u-blox ZED-F9P-04B-01 module. It is intended for equipment manufacturers developing an embedded positioning system around an external GNSS antenna and a host controller.
The module tracks GPS L1 and L2, Galileo E1 and E5b, BeiDou B1I and B2I, and supported GLONASS and QZSS signals. The external antenna can be positioned separately from the receiver PCB, giving designers room to work around enclosure, cable routing and antenna placement constraints.
A compatible RTCM stream from an RTK reference station or correction service enables the module to compute a fixed RTK solution when satellite reception and correction quality are suitable. The host can use the receiver's position output for navigation, guidance or georeferenced data collection.
Dual-Frequency GNSS Reception
The ZED-F9P-04B-01 uses observations from two frequency ranges to support RTK processing. An antenna covering the signals selected for the application lets the receiver use both ranges.
RTCM 3.3 Correction Support
The module accepts compatible RTCM 3.3 messages. System designers can deliver corrections through an existing radio link or through a host that receives a network correction stream.
External Active Antenna Integration
An external active antenna can be placed above the equipment or at another suitable location with good sky visibility. Match its frequency coverage, RF connector and bias requirements to the receiver installation.
NMEA and UBX Message Support
NMEA supports integration with software that expects standard GNSS messages. UBX gives compatible software access to u-blox configuration and receiver status messages.
Four-Point PCB Mounting
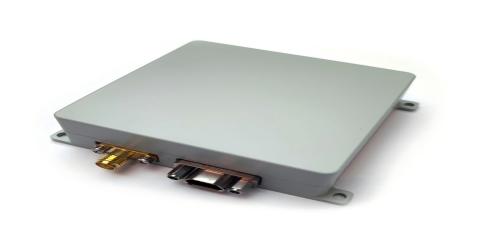
Four corner mounting holes give mechanical designers defined points for securing the board. The threaded RF connector projects beyond the PCB edge, where clearance can be reserved for the mating connector and cable.
| Attribute | Value |
|---|---|
| Product Model | TX-ZED-F9P-04B-MINI |
| Product Type | Compact dual-frequency RTK GNSS receiver board |
| GNSS Module | u-blox ZED-F9P-04B-01 |
| Antenna Requirement | External active dual-frequency GNSS antenna |
| PCB Mounting | Four corner mounting holes |
| GNSS Signals (Module) | GPS L1 C/A and L2C GLONASS L1OF and L2OF Galileo E1-B/C and E5b BeiDou B1I and B2I QZSS L1 C/A and L2C, used with GPS |
| Positioning Modes (Module) | Standalone GNSS and RTK rover positioning |
| RTK Correction Protocol (Module) | RTCM 3.3 |
| Position Data Protocols (Module) | NMEA and UBX |
| Horizontal RTK Position Accuracy (Module, CEP) | 0.01 m + 1 ppm |
| Vertical RTK Position Accuracy (Module, Median) | 0.01 m + 1 ppm |
The accuracy figures are published by u-blox for the ZED-F9P-04B module under its specified test conditions. Installed performance depends on antenna placement, satellite visibility, multipath, distance to the reference station and the quality of the correction stream.
The ZED-F9P-04B-01 module is centered on the PCB. Two board headers sit along one edge, opposite a right-angle threaded RF connector and a miniature coaxial connector. When planning the enclosure, allow clearance for the mating harnesses, coaxial cable bend radius and four mounting points.
UAV Navigation
Integrate RTK position data into a compatible flight-control system with a separately mounted GNSS antenna.
Outdoor Mobile Robots
Supply position updates to a robot controller for outdoor route following and waypoint navigation.
Precision Agriculture Equipment
Prototype positioning subsystems for guidance or field data collection on agricultural platforms.
Surveying and Mapping Hardware
Add an RTK rover receiver to custom instruments that pair location data with survey observations or mapping records.
External GNSS antenna → TX-ZED-F9P-04B-MINI → Host controller
Mount a compatible active GNSS antenna with a clear view of the sky and connect it to the designated RF input. Use the board's pinout to match the supply voltage, host interface and logic levels before wiring. Configure the host to read the required NMEA or UBX messages.
For rover operation, forward compatible RTCM corrections from a base station or a host running an NTRIP client. Use the receiver's solution status to distinguish standalone, RTK float and RTK fixed positions during system testing.
TOXU can help specify the external GNSS antenna, RF connectors and coaxial cable assembly for this board. Share your antenna mounting location, available cable space and required cable length so the receiver and RF interconnects can be selected together.
RF Hardware Selection for OEM Systems
TOXU can review the antenna, cable and connector requirements alongside the receiver layout before the enclosure and harness design are finalized.
Prototype and Volume Manufacturing Support
Discuss project-specific harnesses, RF cable assemblies and PCBA integration for evaluation builds and volume orders.
TOXU Tech supplies GNSS positioning hardware, GNSS and communication antennas, RF connectors and coaxial cable assemblies to equipment manufacturers and system integrators.
TOXU also provides PCBA manufacturing and OEM / ODM integration services for customers developing and producing RF or GNSS equipment.
Which u-blox module is installed on the board?
The TX-ZED-F9P-04B-MINI uses the u-blox ZED-F9P-04B-01 module.
Which GNSS signals should the antenna cover?
Select an active dual-frequency antenna that covers the signals required for the project, such as GPS L1 and L2, Galileo E1 and E5b, and BeiDou B1I and B2I. Check antenna bias requirements and connector compatibility before ordering.
What does the board need for centimeter-level RTK positioning?
Use a compatible active GNSS antenna, a valid RTCM correction stream and a site with suitable satellite visibility. Check that the receiver reports a fixed RTK solution.
Can the receiver provide a position without RTCM corrections?
Yes. The module can provide a standalone GNSS position. Centimeter-level RTK positioning requires a valid correction stream and a fixed solution.
How can the system receive NTRIP corrections?
Run an NTRIP client on a compatible host or communications device, then forward the RTCM messages to the receiver through the configured data interface.
Can the board be integrated with a UAV flight controller?
Integration depends on the host interface, pinout, logic voltage and GNSS message support. Share the flight controller model and harness requirements so the connection can be reviewed.
Lucy Yang | lucy.y@toxutech.com
Dotty Zhao | sales04@toxutech.com
Global Business Director / Sales Team / Global Operations


 En
 Cn
 Korean
 Home >


