-
Products -PCBA Manufacturing RF Connectors RF Cable Assemblys Embedded Antennas External Antennas GNSS Positioning Solutions
RF Connectors

RF Cable Assemblys
Embedded Antennas
External Antennas
GNSS Positioning Solutions
 Language


Language
Model: TX-K803-EK0407
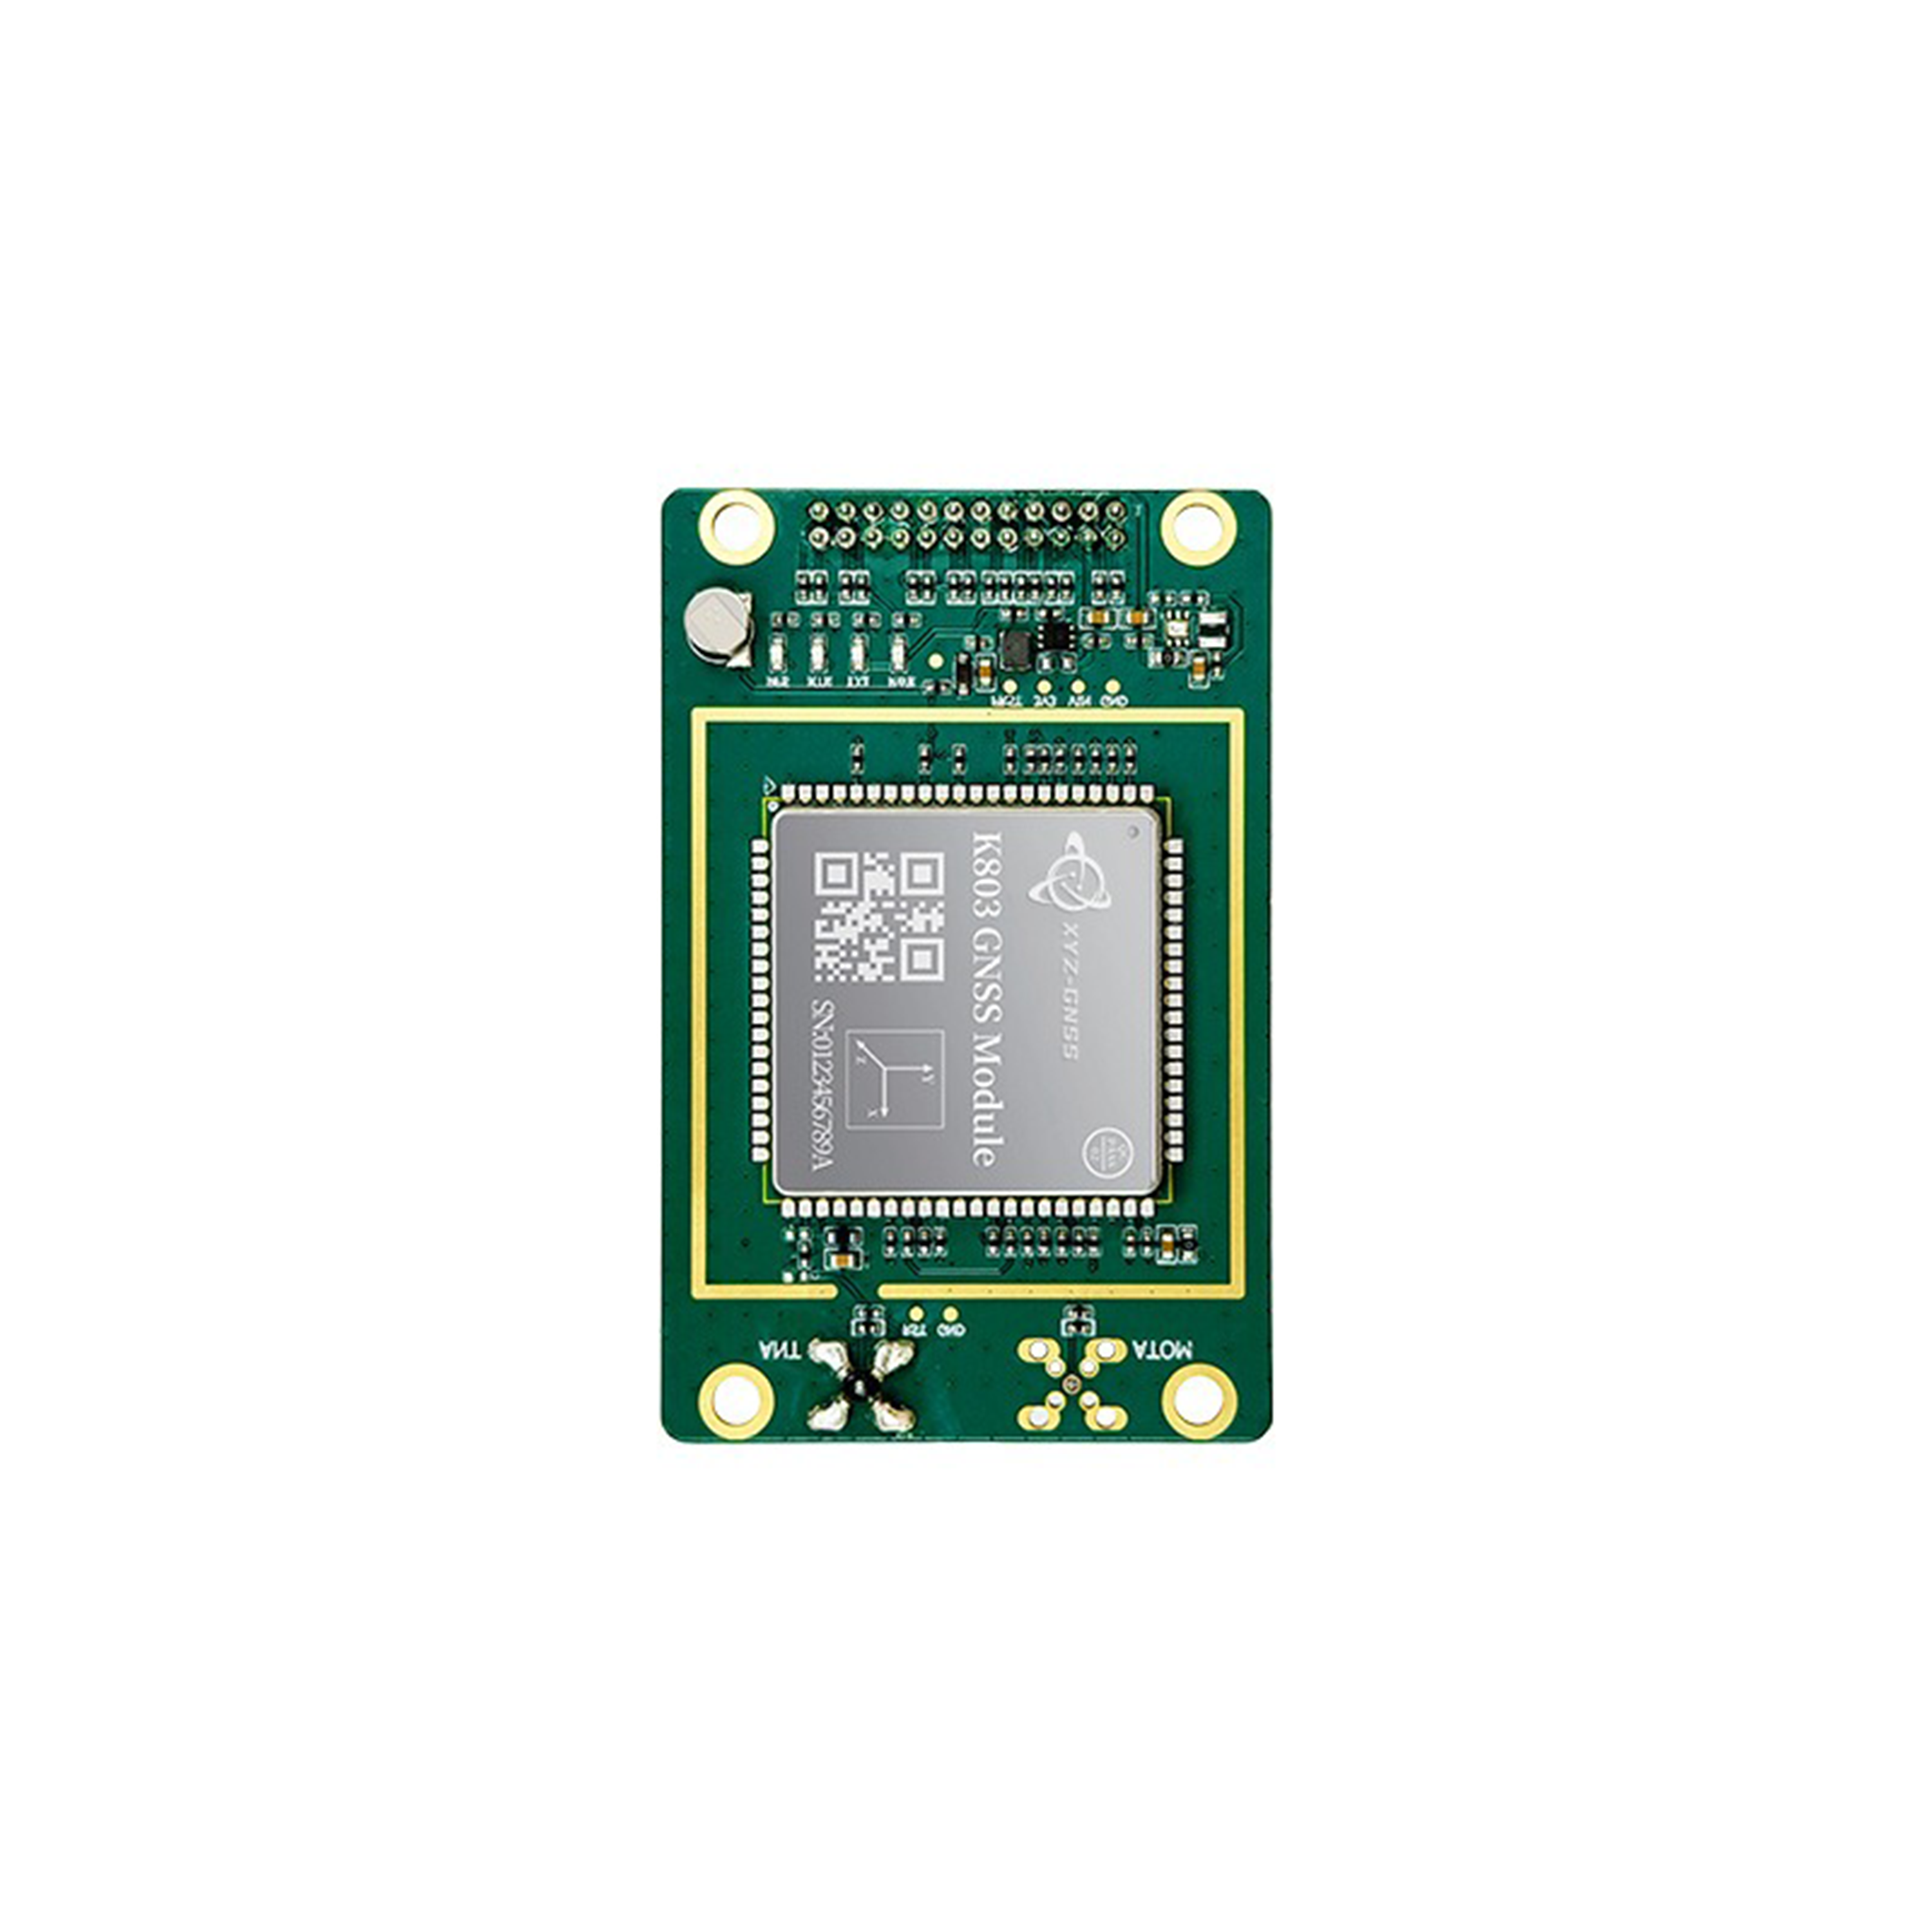
The TOXU TX-K803-EK0407 is a multi-frequency RTK GNSS/INS OEM receiver board built around the K803 module. The EK0407 adapter format provides serial and timing interfaces for integration into robotic platforms, mapping instruments and custom navigation hardware.
Multi-Constellation, Multi-Frequency GNSS
The K803 platform tracks GPS, BeiDou, GLONASS and Galileo signals across multiple frequency bands.
RTK Positioning
Evaluate centimeter-level positioning with a suitable GNSS antenna, compatible corrections and favorable satellite reception.
GNSS/INS Integration
The inertial-navigation configuration combines GNSS observations with onboard IMU measurements for navigation development.
Serial and Timing Access
The EK0407 platform provides three LVCMOS serial interfaces, PPS and event inputs for compatible host systems.
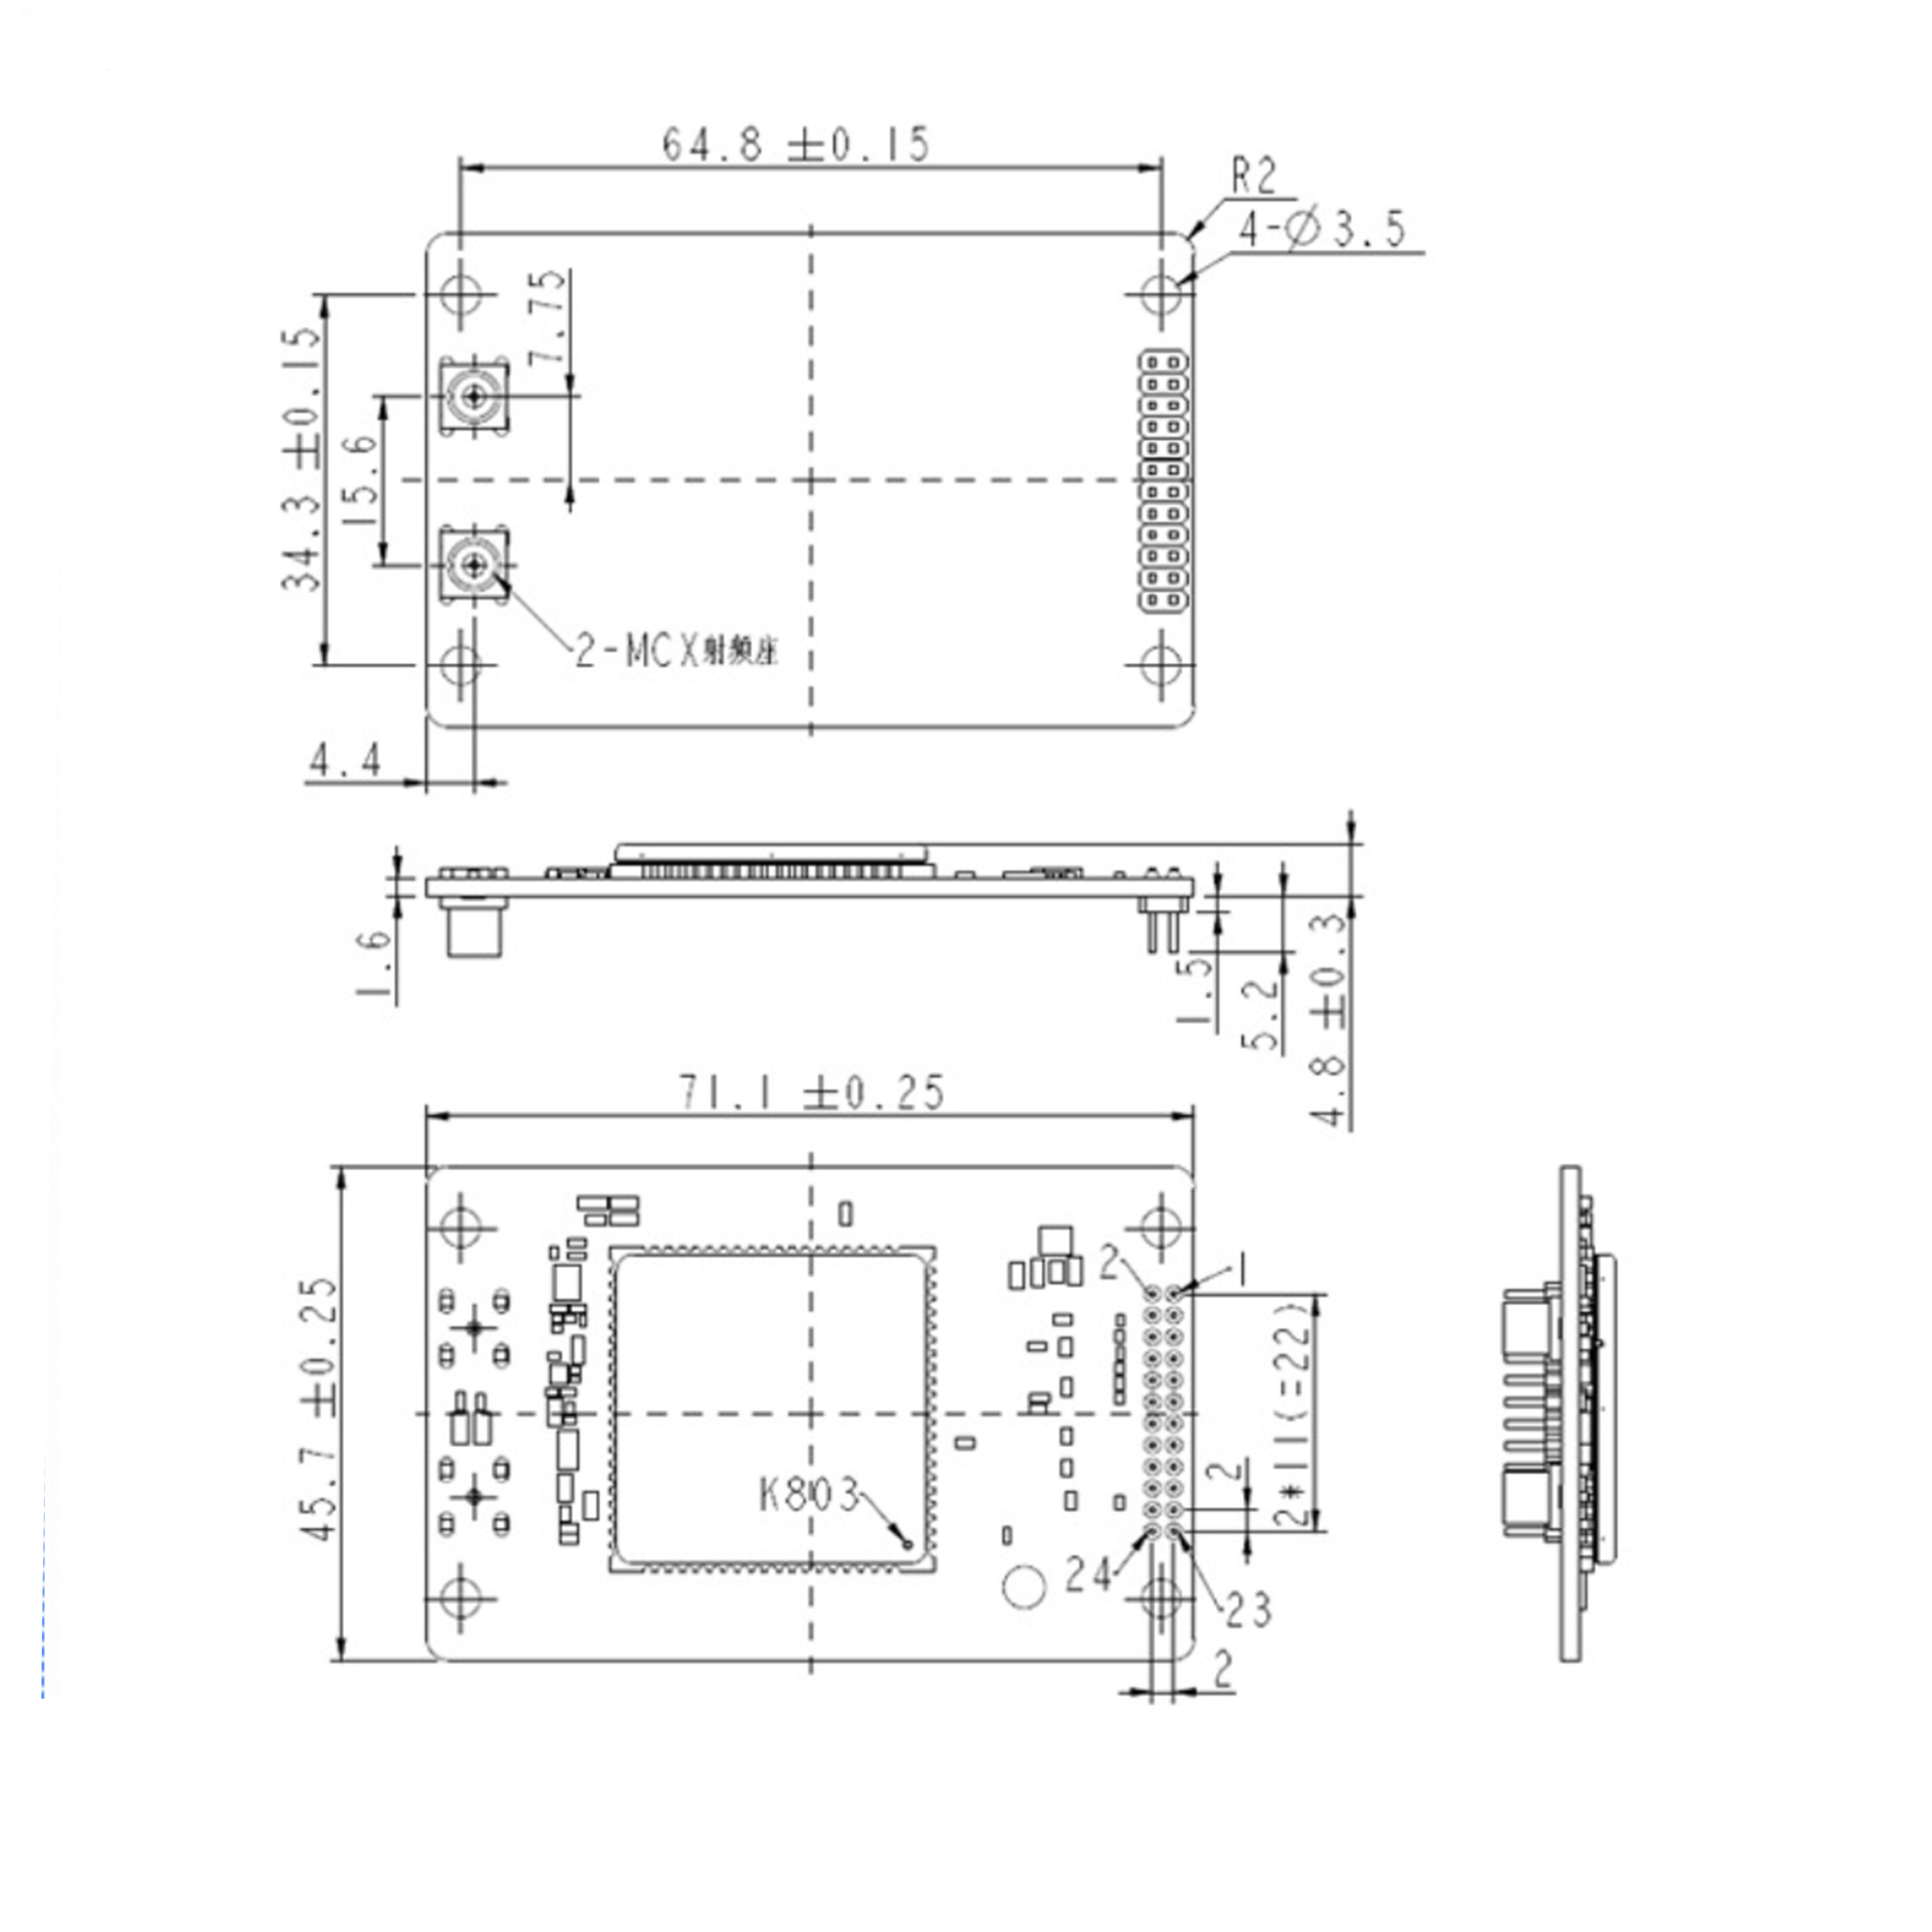
46 × 71 mm OEM Board Format
Four corner mounting holes and a 2 × 12 interface footprint support installation on a carrier board or mounting plate.
The TOXU TX-K803-EK0407 is an OEM receiver board combining a K803 GNSS module with an EK0407 adapter PCB. It gives equipment manufacturers a board-level platform for evaluating RTK positioning, inertial integration and host communication.
The K803 platform supports multi-constellation, multi-frequency GNSS reception, including GPS L1/L2/L5, BeiDou B1/B2/B3 and Galileo E1/E5 signals. With compatible correction data and suitable antenna reception, the module can compute centimeter-level RTK positions.
The GNSS/INS configuration uses onboard inertial measurements alongside satellite observations. Developers can evaluate navigation behavior under changing reception conditions while accounting for mounting orientation, initialization and the motion characteristics of the platform.
The EK0407 adapter exposes serial and timing connections through an OEM interface footprint. It is intended for integration into a host system with the required power supply, RF connection and communication wiring.
Multi-Frequency Satellite Tracking
The K803 receiver processes signals from several GNSS constellations and frequency bands. A matching multi-band antenna lets the receiver use the signals selected for the application.
RTK Rover Integration
Deliver compatible correction data to the receiver through the host system or an external data link. The host can use the resulting position and solution status for navigation or georeferenced measurement.
GNSS and Inertial Measurements
The inertial-navigation configuration supports evaluation of fused GNSS and IMU data. Rigid installation and correct sensor-axis alignment are part of the integration process.
Three LVCMOS Serial Interfaces
The EK0407 platform provides serial access for compatible embedded hosts and correction-data connections. Match the logic levels and configured messages to each connected device.
PPS and Event Interfaces
PPS provides a timing reference for compatible host hardware. Event inputs support timestamping of external triggers for applications such as mapping and synchronized data acquisition.
OEM Adapter Board Layout
The 46 × 71 mm EK0407 format combines four mounting holes with a 2 × 12 interface footprint. The configuration shown has unpopulated interface and RF connector footprints for integration into a project-specific assembly.
| Attribute | Value |
|---|---|
| Product Model | TX-K803-EK0407 |
| Product Type | RTK GNSS/INS OEM receiver adapter board |
| GNSS Module | K803 |
| Adapter Platform | K803_EK0407 |
| Navigation Configuration | GNSS positioning with inertial-navigation capability |
| PCB Dimensions | 46 × 71 mm, EK0407 platform specification |
| Input Voltage | 3.3–5.5 V DC, EK0407 platform specification |
| Serial Interfaces | 3 × LVCMOS |
| Timing Interfaces | 1 × PPS 2 × EVENT |
| Host Interface Footprint | 2 × 12 positions, 2 mm pitch |
| Mounting | Four corner mounting holes |
| Connector Configuration Shown | Unpopulated host-interface and RF connector footprints |
| GPS Signals (K803 Module) | L1 C/A, L1C, L2P, L2C and L5 |
| BeiDou Signals (K803 Module) | BDS-2 B1I, B2I and B3I BDS-3 B1I, B3I, B1C, B2a and B2b |
| GLONASS Signals (K803 Module) | G1 and G2 |
| Galileo Signals (K803 Module) | E1, E5a and E5b |
| Horizontal RTK Accuracy (K803 Module) | 8 mm + 1 ppm |
| Vertical RTK Accuracy (K803 Module) | 15 mm + 1 ppm |
| Data Formats (K803 Module) | NMEA 0183, ComNav Binary and supported RTCM formats |
The RTK accuracy figures are published module specifications. Installed performance depends on antenna quality, satellite visibility, multipath, reference-station distance and correction quality. Inertial-navigation performance also depends on calibration, motion and the duration of reduced GNSS availability.
The K803 module occupies the central area of the adapter PCB. The host-interface footprint sits at one end, with RF connector footprints at the opposite end. Four corner mounting holes provide attachment points for a carrier plate or enclosure.
For inertial integration, mount the board rigidly and document the relationship between the marked sensor axes and the platform coordinate system. Include connector access, RF cable routing and board clearance in the mechanical layout.
Outdoor Robotics
Evaluate RTK position and inertial integration for outdoor robotic navigation and motion monitoring.
Surveying and Mapping Instruments
Pair position data and event timing with measurements collected by a custom mapping or survey instrument.
UAV Navigation Development
Integrate the receiver with a compatible host or flight-control system for positioning and data-recording evaluation.
Machine Guidance
Develop a positioning subsystem for agricultural or industrial equipment using a matched antenna and correction-data link.
Multi-band GNSS antenna → TX-K803-EK0407 → Compatible host controller
Provide regulated power within the board's specified range and connect the host through a compatible LVCMOS serial interface. Match the antenna, RF connection and antenna power arrangement to the receiver installation.
For RTK rover operation, route compatible corrections from a reference station or correction service to the configured receiver port. For GNSS/INS evaluation, complete the required initialization and mounting alignment, then check navigation output under the expected motion and reception conditions.
TOXU can help select a multi-band GNSS antenna, RF cable assembly and connectors for the receiver. Share the host interface, antenna location, cable length and mechanical layout when requesting a quotation.
Receiver and RF Hardware Selection
Review the receiver, antenna and RF interconnects together before finalizing the carrier board and enclosure.
Prototype and Production Configuration
Define the module version, enabled functions and connector assembly during sample evaluation so the agreed configuration can be specified for repeat orders.
TOXU Tech supplies GNSS positioning hardware, GNSS and communication antennas, RF connectors and coaxial cable assemblies for equipment manufacturers and system integrators.
TOXU also provides PCBA manufacturing and OEM / ODM hardware integration services for RF and GNSS projects, from prototype assemblies through volume production.
What is included in the TX-K803-EK0407 board?
The board combines a K803 GNSS module with an EK0407 adapter PCB. The configuration shown has unpopulated interface and RF connector footprints.
Does the receiver support RTK positioning?
Yes. The K803 module supports RTK positioning with compatible corrections, a suitable antenna and sufficient satellite reception for a fixed solution.
What is the role of inertial navigation?
In the inertial configuration, IMU measurements are combined with GNSS observations. Performance depends on initialization, installation alignment, platform motion and satellite availability.
Can the serial ports connect directly to RS232 equipment?
Use an appropriate level-conversion circuit when connecting the board's LVCMOS signals to an RS232 interface.
What are the PPS and event interfaces used for?
PPS provides a timing reference. Event inputs allow compatible external triggers to be timestamped by the receiver.
How is the board installed for inertial evaluation?
Use a rigid mounting arrangement and configure the sensor-axis alignment according to the supplied integration instructions.
Can TOXU supply matching antennas and cables?
Yes. Provide the required frequency coverage, antenna mounting arrangement, RF connector and cable length for selection.
Lucy Yang | lucy.y@toxutech.com
Dotty Zhao | sales04@toxutech.com
Global Business Director / Sales Team / Global Operations


 En
 Cn
 Korean
 Home >


